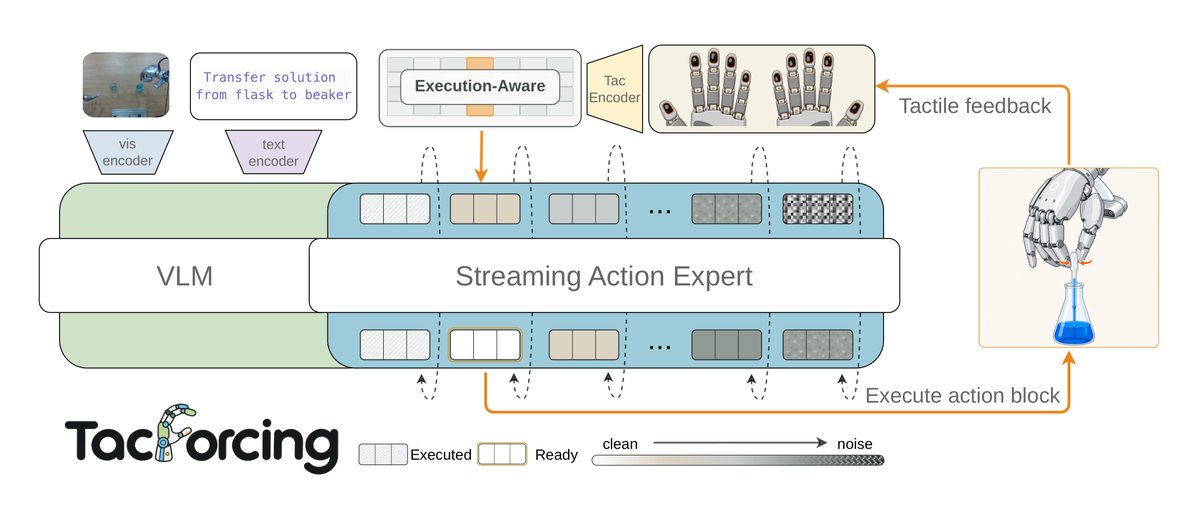
TacForcing: Streaming Action Generation with Execution-Time Tactile Feedback
arXiv preprint arXiv:2608.25798, 2026arXiv 预印本 arXiv:2608.25798,2026
Lets a robot react to what it feels while it moves, instead of only planning from what it felt beforehand. 让机器人在动作进行当中就能对触感做出反应,而不是只凭动作开始前摸到的东西来规划。